Opsy DuckRebuilt. And it really walks.
A personal, non-commercial research build — matched to the original as closely as the public evidence lets us.
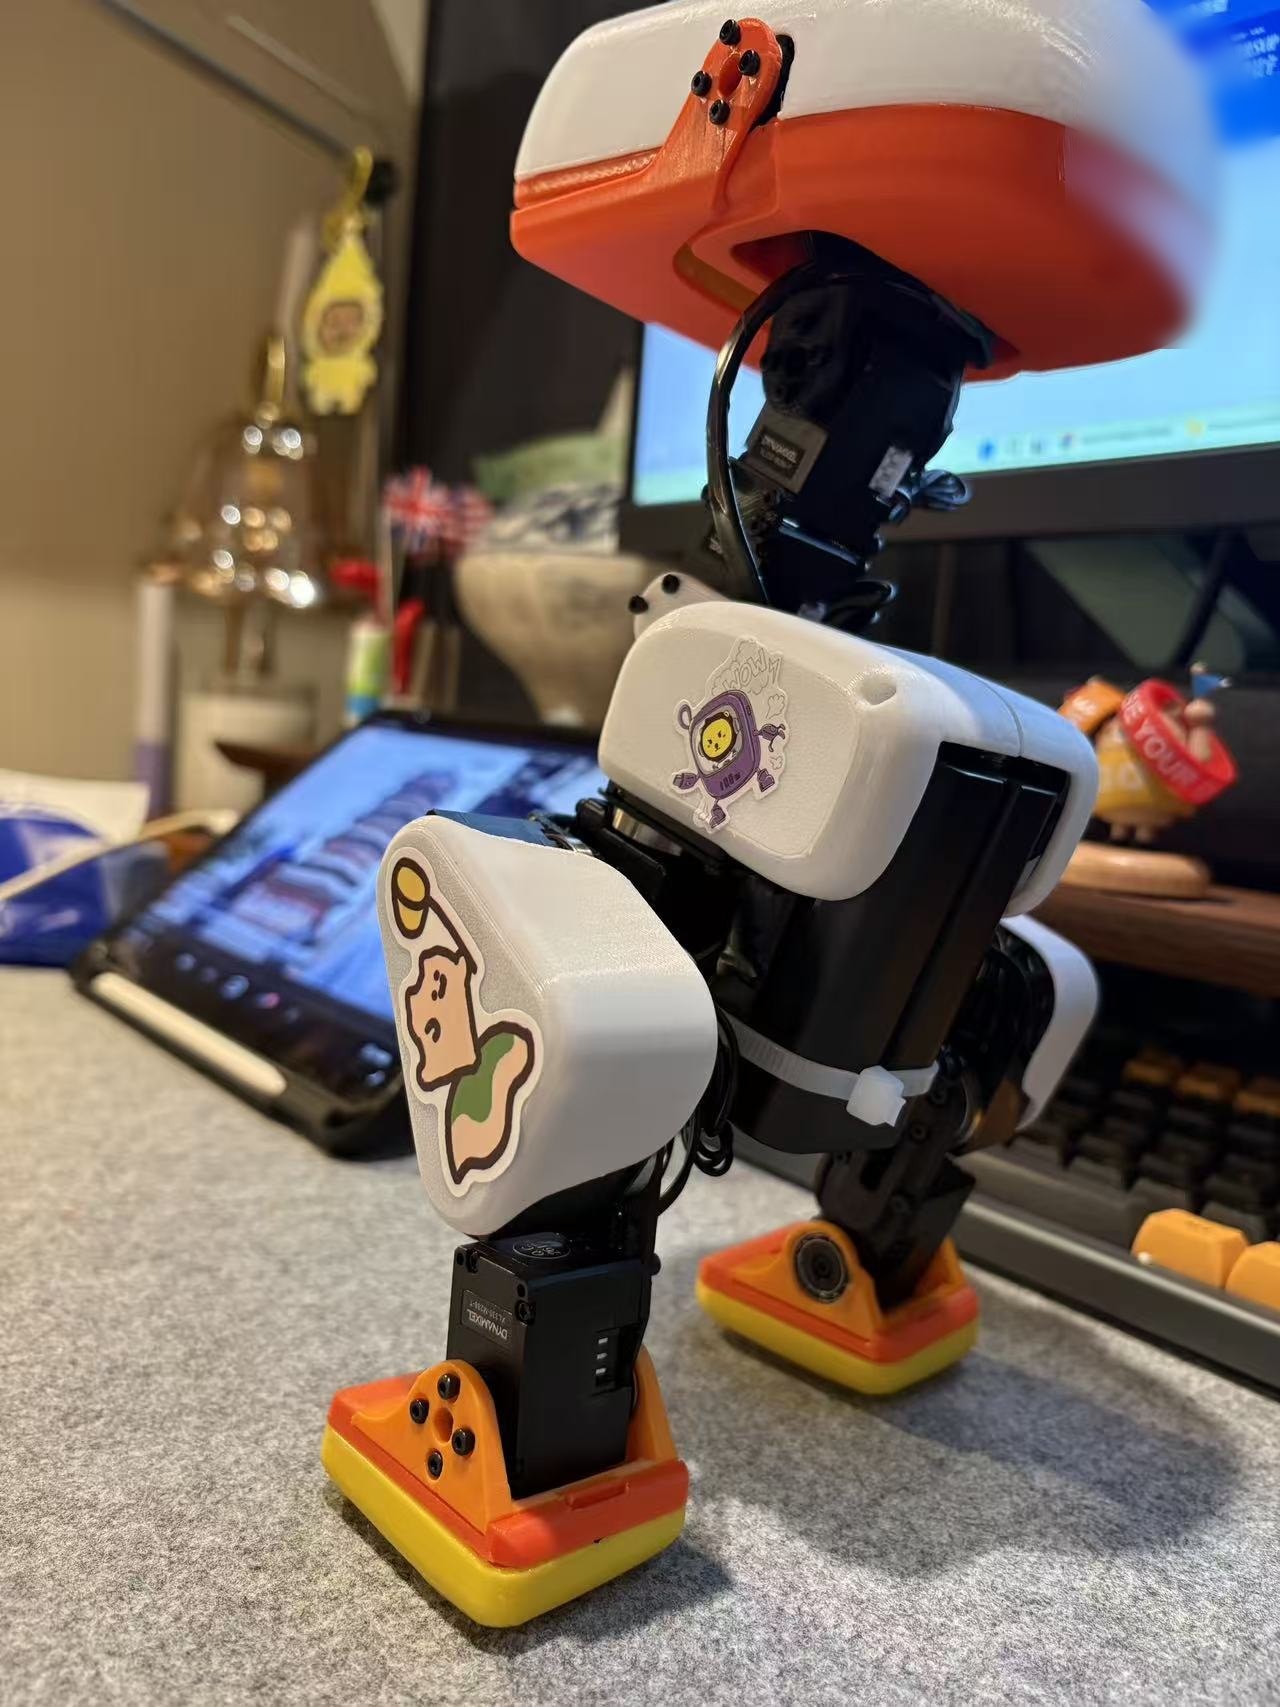
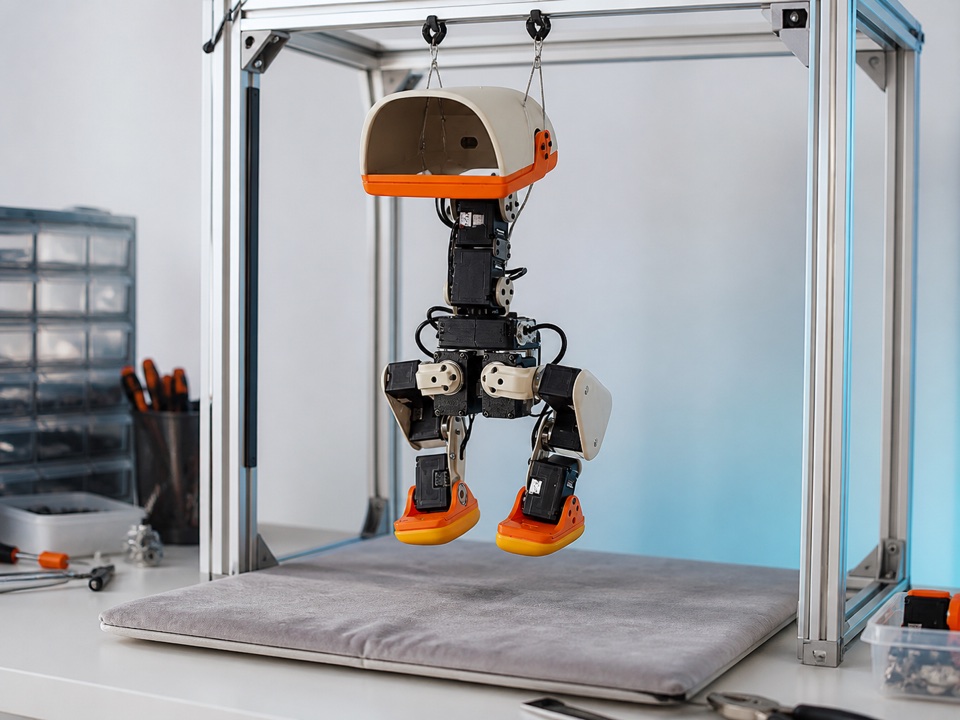
Rebuild complete · the real robot on camera
All tests passed · 2026.09.14
Project goals
Three goals.One build.
Build progress
Where the build stands
Complete · stage 8 / 8
All 9 official policies passed
Latest build
2026.09.14 · Rebuild complete
Build complete · 2026.09.14
Rebuild complete. Every test passed.
08 / 08
Mechanical build
Complete
Project status
Rebuild complete
Latest checks
All 9 official policies tested on the robot
Standing was just the start. More moves unlocked.
All 9 official policies tested on the real robot — here it is out for a walk.
- Walking
- Stand & pose
- Sit-to-stand
- Ground pick
- Left kick
- Right kick
- Roller drive
- Roller crouch
- Forward roll
Meet our duck
Meet our duck.
Built for real. Here are a few close-ups.
Swipe or tap to see all 8 stages →
04 / Software & Ducklink
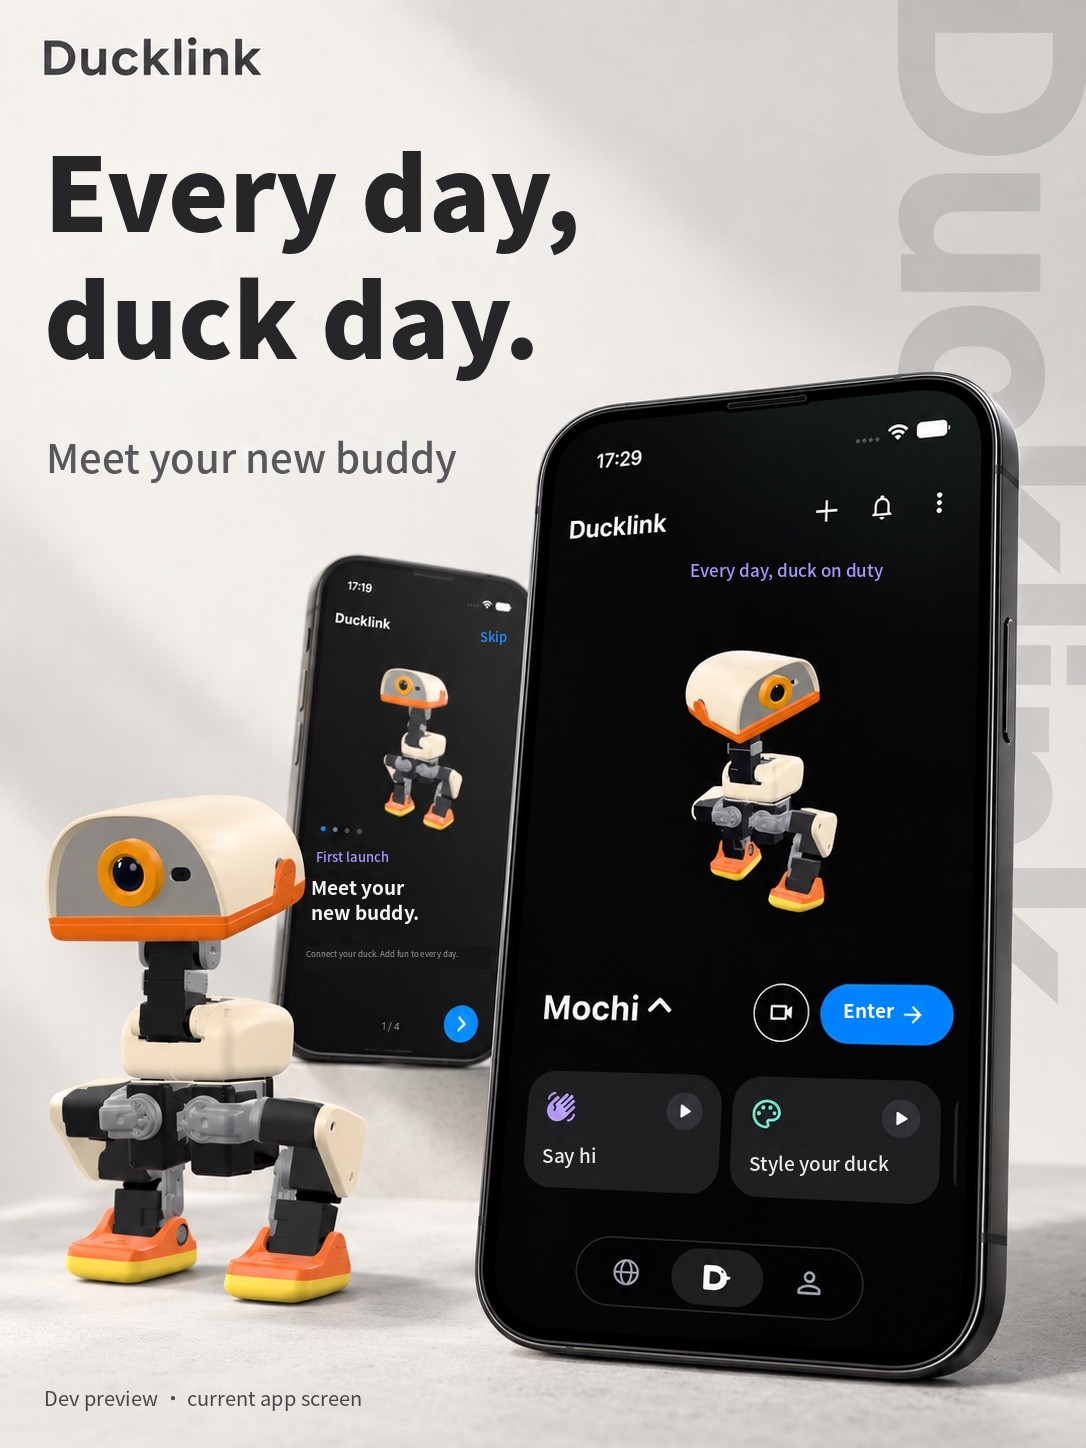
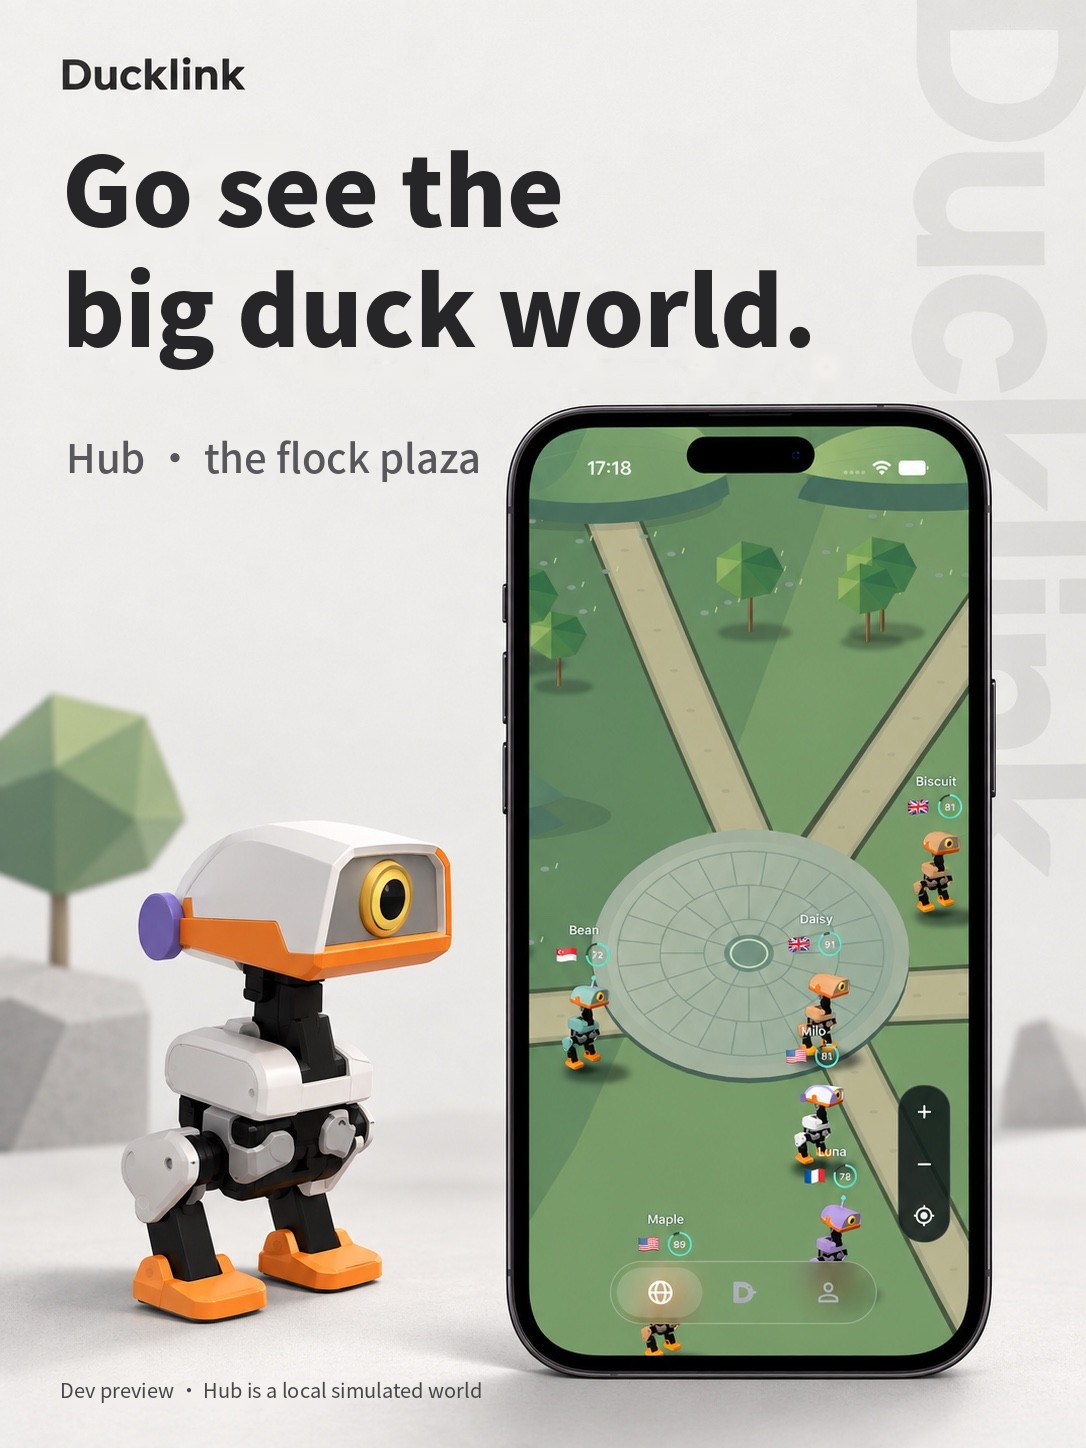
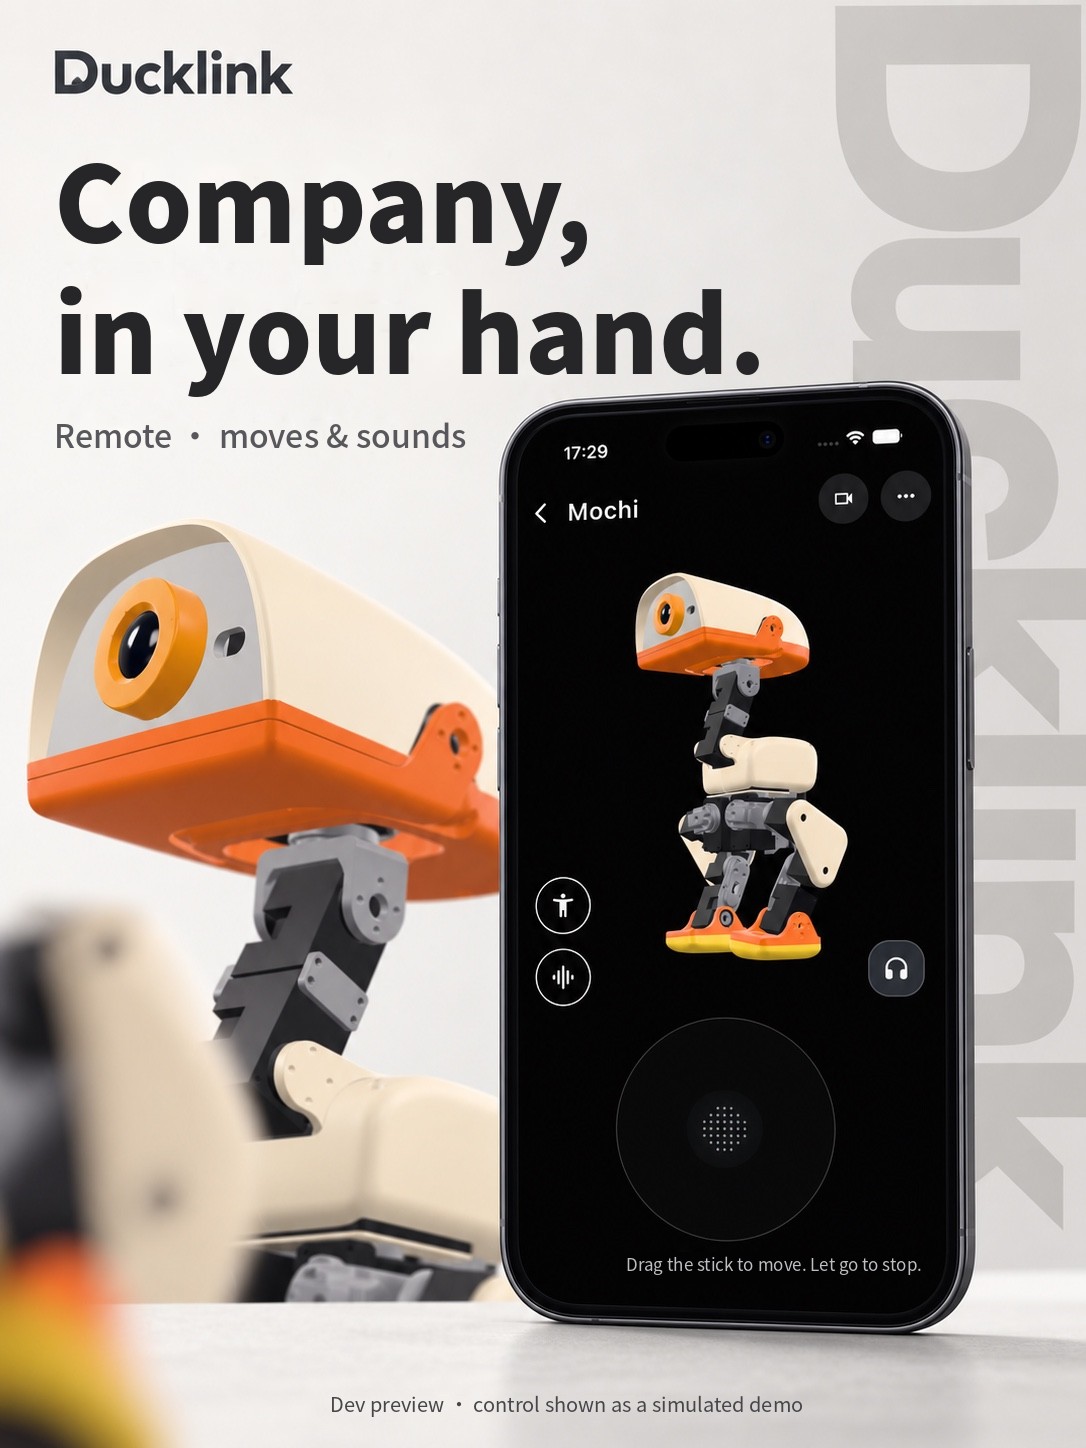
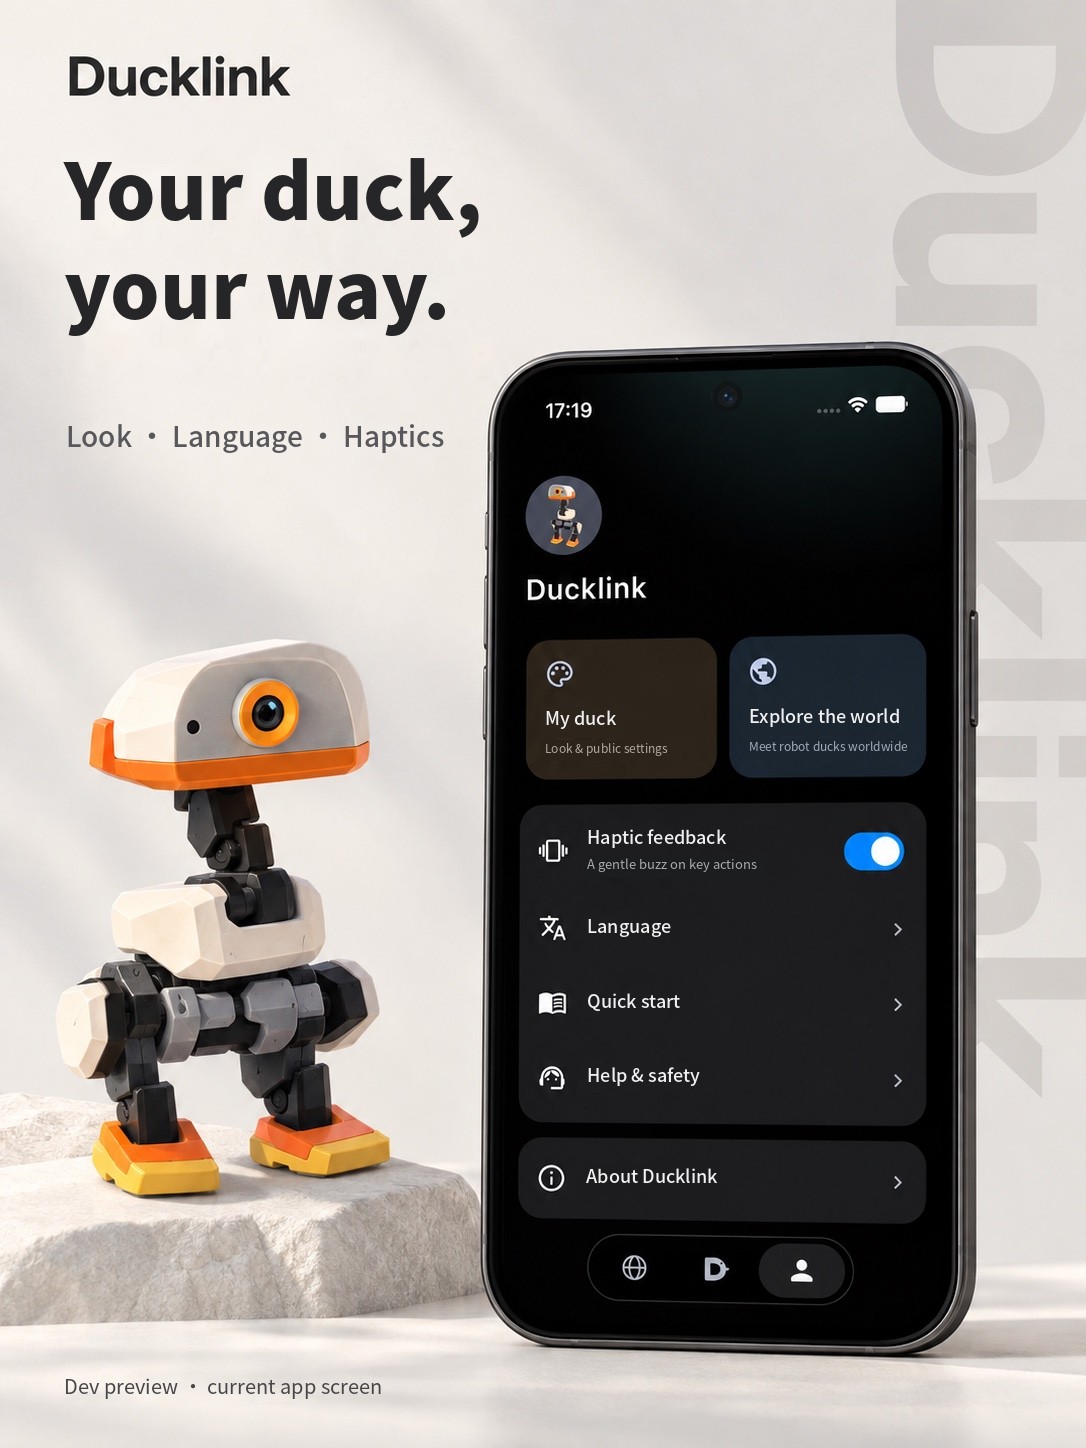
Our first cross-platform app
Ducklink
Every duck, connected.
From the duck on your desk to a flock around the world — we're building one home to connect, control, and manage every Opsy Duck.
- Phone · Tablet · Desktop
- Live video and online control
- Battery, temperature, and memory management
- Apps, driver updates, and voice wake-up
01 / 04
Your duck
Software's ready. The add-ons are coming online.
Radxa ZERO 3W · board update 2026.09.06
 First selfie · 09.06First selfie
Official stable release
daemon v0.10.0
Armbian 26.2.1 · Debian 13.3 · ARM64
Signatures and all 52 release files checked.
9
trained policies
82
sound files
0
missed fake-mode ticks
01RL policies
Robot-testedEvery one of the nine official policies in this build passed on the robot: walking, standing and body-pose control, sit-to-stand, ground pick, left kick, right kick, roller locomotion, roller crouch, and forward roll.
2026.09.16 · results confirmed by the project lead
02NPU vision inference
RunningThe official duck_detect model finished on-board inference across 14 official images.
4 detections · p50 46.3 ms · 0 runtime errors · not a camera test
03Camera and video stack
First capture passedThe IMX219 took its first 1280×720 capture, and 60 frames of a 720p test pattern also cleared hardware encoding.
2026.09.06 · basic capture and orientation passed · live streaming next
04Controller and audio
Hardware verifiedThe Xbox controller, the onboard microphone, and the 4 Ω / 3 W speaker all passed real-hardware checks.
82 WAV files · 40+ seconds of non-stop official-sound playback passed
Next software
Play roadmap
- 01 Real-hardware bring-up
- 02 Controller-driven actions
- 03 Camera perception
- 04 Audio and character interaction
- 05 Voice wake-up
- 06 Battery monitoring
- 07 Head-mounted display